Software has enabled a new level of capability in modern vehicles. ADAS, over‑the‑air updates, and connected user experiences are no longer emerging concepts—they are already part of today’s vehicles.
The challenge now is not what software can do. It is how those capabilities are scaled across vehicle platforms and over time—without creating system complexity that limits performance, safety, and future evolution.
Every new function introduces additional demands. More data must be processed. More systems must communicate. More capabilities must share common computing resources. More software must be validated, secured, and maintained throughout the vehicle lifecycle. Without the right foundation, complexity grows faster than capability.
Architecture Defines What Scales
That shift is redefining the role of vehicle architecture.
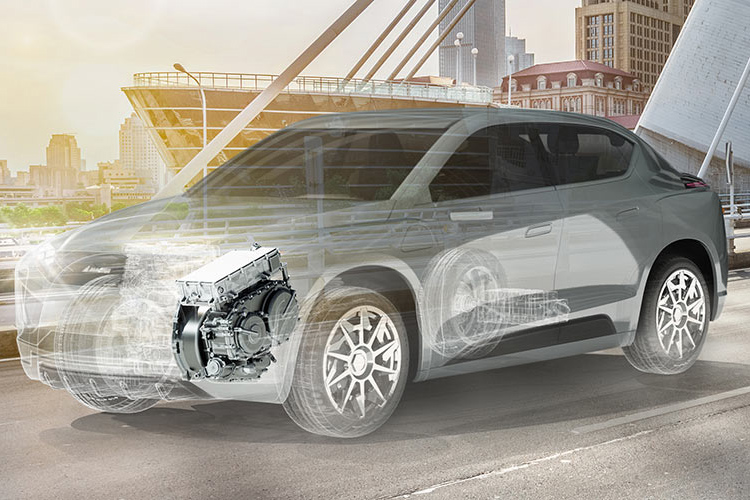
In software‑defined vehicles (SDVs), architecture determines how compute, networks, sensors, and software environments are structured and shared across the system. For decades, vehicle functions were developed largely within their own domains, often supported by dedicated hardware and independent development paths.
SDVs fundamentally change that model. Modern vehicle platforms rely on centralized compute, shared software environments, and interconnected systems that must operate as a unified whole.
Success is no longer defined by optimizing individual components. It depends on how effectively the full system works together.
Architecture is what makes that possible. It determines whether new capabilities can be deployed efficiently, scaled reliably, and sustained over time. Without it, adding functionality increases complexity at a rate that is difficult to manage. With it, capability can be integrated, validated, and extended in a controlled and scalable way.
Integration Becomes the Core Discipline
This is where systems integration becomes the central engineering challenge.
In SDVs, integration is no longer a downstream activity. Systems do not operate independently, and decisions in one domain increasingly affect performance across many others. ADAS, sensing, connectivity, and user experience all depend on shared compute resources, sensor data, and common software platforms.
That level of interdependence changes how vehicles must be engineered. A new sensing capability can increase bandwidth and compute demand. A software update can shift how resources are allocated across multiple functions. Additional features can introduce new requirements for power, thermal management, and validation.
The challenge is no longer simply adding capability. It is ensuring those capabilities work together as part of a cohesive system.
Systems integration is no longer a supporting function. It is a core engineering discipline—one that determines whether SDV platforms can scale without compromising performance, safety, or reliability.
Designing for Continuous Evolution
At the same time, expectations around how vehicles behave are changing.
SDVs are not engineered to be complete at launch. They are designed to evolve. Customers increasingly expect vehicles to improve over time through updates, new functionality, and enhanced performance.
Meeting that expectation requires a different approach to engineering. Teams must design not only for current requirements, but for future demands that may not yet be fully defined. That means building sufficient compute headroom into the platform, designing networks that can support increasing data flows, and developing validation strategies that allow software to evolve without compromising safety or reliability.
The goal is no longer just to deliver a vehicle at launch. It is to create a platform that can adapt and improve throughout its lifecycle.
The Platforms That Win
The opportunity in SDVs is not simply adding more software. It is creating platforms that can continuously evolve while managing the complexity that evolution introduces.
Achieving that requires more than software expertise. It requires the ability to bring together hardware, software, sensors, compute, networking, validation, and vehicle engineering into a cohesive system from the start. It requires architecture designed for scale, and integration executed as a core capability.
The companies that succeed in the SDV era will not be defined by the features they deliver, but by the architectures they build to sustain them.
Software may define what a vehicle can do.
But systems integration determines what it can become.
To learn more about Magna's electronics and software-enabled vehicle technologies, visit www.magna.com/products/electrical-electronics/adas---automated-driving.